Dynamic Manipulation with World-Action Models via Counterfactual Planning
arXiv preprint (under review)
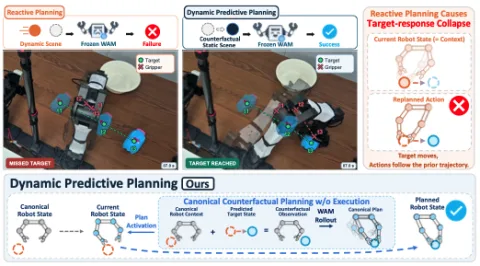
Dynamic Predictive Planning treats manipulation of moving targets as counterfactual planning: the world-action model's own rollout estimates when an interaction will happen and where the target will be, and a counterfactual observation lets the policy invoke a skill it already has instead of improvising a recovery. Runs in real time on a single consumer GPU with no training on dynamic data.